Home
Products
Contact
Home
Products
Contact
Home
/
LIDAR
/ ME
ME
SLAM RTK
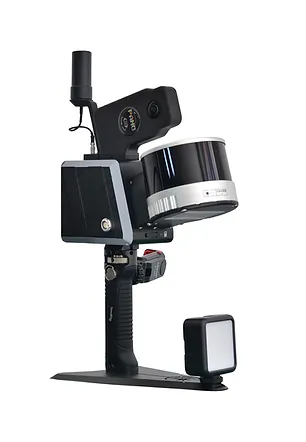
GNSS RTK Hybrid Supreme model, serving as a SLAM-based RTK rover and an RTK-based
📥 Data Sheet Download
Share:
Description
Specs
Description
Specification
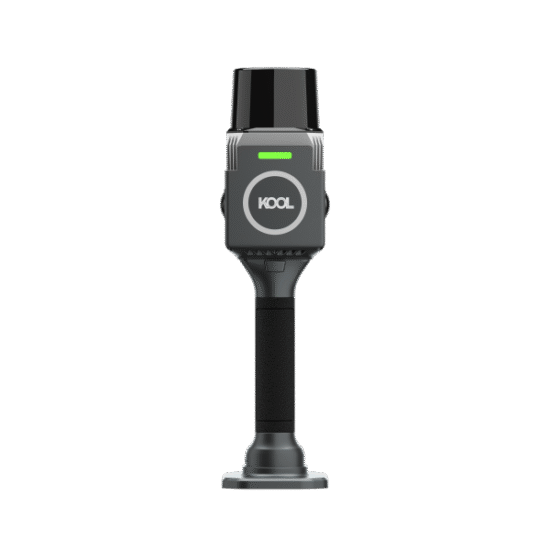
KOOL Handheld 3D Laser Scanner
Scan Range
0.1-40m @10% reflectivity; 0.1-100m @90% reflectivity
FOV
360°(H.)x130°(V.) optimized for data redundancy
Scanner Sensor
Mixed solid-state laser with stable internal structure
Mapping Method
SLAM, with realtime point cloud display
Process Mode
Realtime and post-process both
Scan Rate
200,000 pts/sec (equivalent to 1.2 million pts/sec resulted from non-repetitive scanning and exclusive vari-frequency tech)
Laser Class
Class-1 eye-safety
Camera Lens
2x 12MP
Fieldwork Control
MapStar
Data Process
AcuteLas Studio
Accuracy Performance
≤1cm relative accuracy
Geo-referencing
Control points establishment for localization
Power Supply
Handgrip battery, 3,150mAh, 45.36Wh
Power Consumption
23W
Endurance
150 min
Data Management
TF card and Type-C
Memory Capacity
128 GB, expandable
Ingress Protection
IP5X
Net Weight
1.12 kg
Dimension
111x222x33 mm
Working Temperature
-20℃ to 45℃
Storage Temperature
-20℃ to 45℃
Related products
KOOL SLAM
KOOL SLAM
,
LIDAR
KOOL Handheld 3D Laser Scanner Model: KOOL Handheld 3D Laser…
RobotSLAM Standard
LIDAR
Professional SLAM 16 / 32 channels 120m measuring range 320,000…
RobotSLAM Lite
LIDAR
Entry-level SLAM Measurement Rate Reach 200,000pts/sec & Measuring Range Up…